A simpler robot, built around what V1 needs.
Remote driving. Onboard perception. A powered load-bearing jaw. A removable bin.
The current design replaces the earlier, more expensive assembly with a plywood-and-timber frame, catalog motors and wheel supports, and selected printed mounts. Its accepted planning material estimate is $604.29, including $11 of unresolved fitting and price allowances. Owned material is counted; freight, tax, tools and labor are separate. This is a build estimate, not a sale price.
Open the V1 simulation lab · beta → Inspect the assembly · beta →
Current geometry. Physics you can explore.
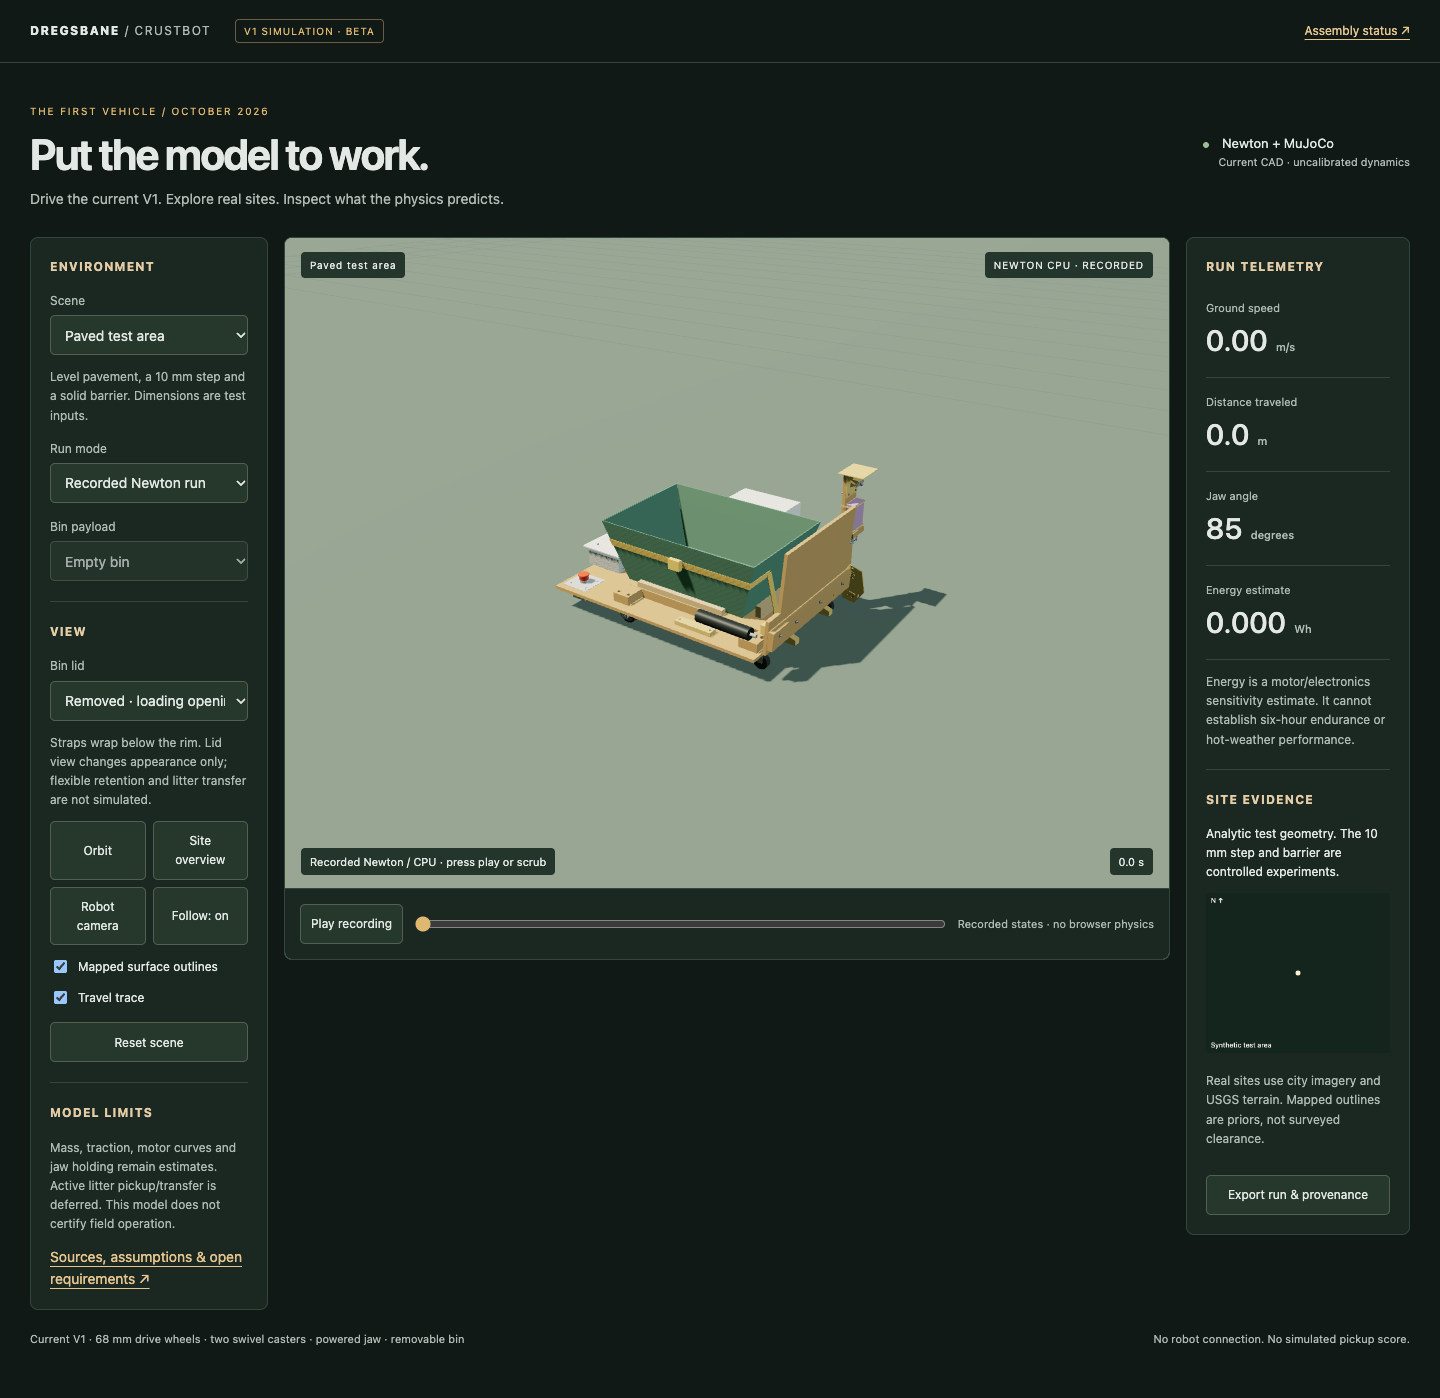
The lab brings the current CAD into recorded Newton runs and interactive MuJoCo physics. Explore the paved test area and two mapped Fredericksburg sites, switch between orbit and robot-camera views, and inspect motion and estimated energy.
Mass, traction, motor curves and jaw behavior remain uncalibrated. Site imagery and terrain are dated geographic references. Simulation does not establish field safety, payload, hot-weather performance or six-hour runtime.
Ready to start the frame.
- Phase 0 CAD & software assembly package saved · desktop checks pass
- Phase 1 frame assembly instructions ready · unpowered build
- Phase 2 powered trials part fitting and physical tests pending · no field date
Integrated CAD, workshop drawings, a four-page bench packet, eight P1S print projects and wiring instructions are prepared. The bin straps now wrap below the rim, keeping its loading opening clear. Delivered-part fits and physical retention still need checking.
V1 retains the Pi 5 / IMX219 perception stack and Pico 2 control. Automatic litter pickup, scoop-to-bin transfer and autonomous navigation remain future work. No completed powered field trial or field pickup is recorded.